You need to test, we're here to help.

You need to test, we're here to help.
Showing posts with label CANbus. Show all posts

27 February 2023

The Case for CAN XL in 10 Mbit/S In-vehicle Networks

CAN XL has recently emerged as a contender in the 10 Mbit/S in-vehicle network space, along with 10Base-T1S Automotive Ethernet. What does CAN XL bring to earn its place on the vehicle bus?

CAN XL builds upon the foundation of CAN and CAN FD, both protocols with a long history in the automotive industry. Figure 1 summarizes the characteristics of the three CAN variants.
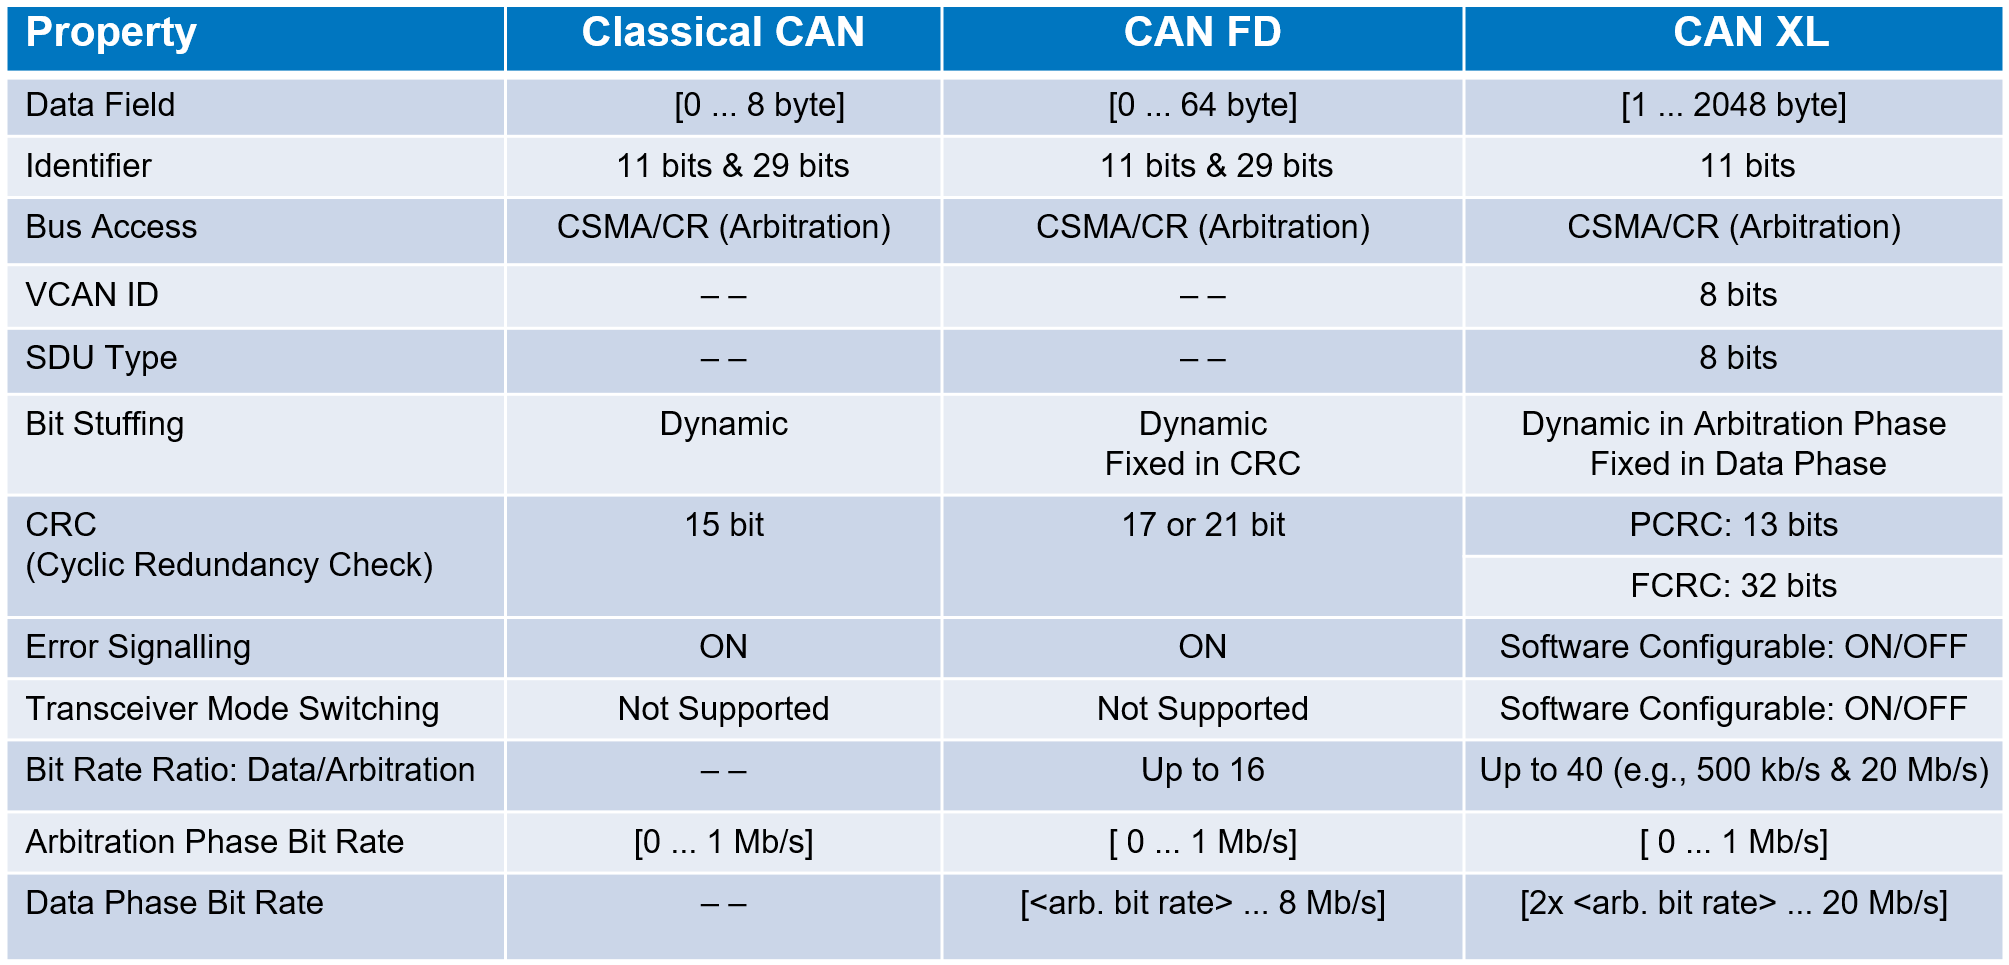
Figure 1. A comparison of the characteristics of CAN, CAN FD and CAN XL
Figure 1. A comparison of the characteristics of CAN, CAN FD and CAN XL.

CAN XL increases throughput with a Fast Mode bit rate of 20 Mbit/S in the data phase, while it operates at 1 Mbps in the arbitration phase (those fields other than data). Another feature contributing to the improved bandwidth of CAN XL is the increased data field maximum length of 2048 bytes compared to 64 bytes for CAN FD and 8 bytes for classic CAN.

20 February 2023

The Evolution of In-vehicle Network Architectures

The drive for fuel-efficient and safer vehicles opened the door to electronic control in vehicles, which in turn led to the deployment of In-vehicle Networks (IVN).  IVNs have become the backbone of modern vehicles. The volume of data flowing through these networks is increasing exponentially with demands for electric vehicles, advanced driver assistance systems (ADAS), radar, lidar, infotainment systems, cameras and vehicle-to-vehicle communications systems.  

To meet this need, the automotive industry—working with technology suppliers—has developed specialized communications protocols and application-specific extensions to existing network technologies, standardized under the aegis of organizations like ISO and IEEE, and it continues to investigate new topologies and protocols to improve performance, increase reliability and lower the costs of IVNs. Two recent developments have filled a longstanding gap in IVN architectures: CAN XL (up-to-20 Mbit/S extended length CAN) and 10Base-T1S (10 Mbit/S single-pair Ethernet), both of which operate in the 10 Mbit/S network space. What problems do these protocols solve and what opportunities do they present for IVN design?

07 August 2018

About Ground Bounce and How to Measure It

Shown are five I/O drivers within a package driving signal lines on a PC board
Figure 1: Shown are five I/O drivers
within a package driving signal
lines on a PC board
Designing and/or troubleshooting a system with, say, an MCU driving signals across transmission lines, can be an interesting exercise in patience and diligent sleuthing. Perhaps you're seeing an inordinate amount of bit errors at the receive end of I/O lines but having some difficulty nailing down the source. In many cases, the problem is ground bounce, an issue that can be tough to diagnose and cure. Let's begin an examination of the ground-bounce phenomenon by explaining how it arises and then outlining an approach for finding it.

08 May 2018

Debugging CANbus For IoT Devices

Temperature data from thermocouples is shown both encoded and decoded on the oscilloscope's display
Figure 1: Temperature data from
thermocouples is shown both
encoded and decoded on the
oscilloscope's display
A myriad of serial-data standards come into play when we're discussing Internet of Things (IoT) devices. We've talked about I2C, SPI, and UART in a previous post. Yet another serial-bus standard that comes under the IoT umbrella is the Controller Area Network (or CANbus) standard. CANbus enables microcontrollers and peripheral devices to communicate with each other in applications without an intervening host computer. In the past, it's been typically used in automotive applications, but CANbus has found its way into a wider scope of applications of late.